 Deutsch
 English
 Français
 Italiano
 Español
 Nederlands
 Polski
 Svenska
 Türkçe
 Čeština
 Português
 Dansk
 Suomi
 Norsk
 Română
 Magyar
 Ελληνικά
 Slovenčina
 Български
 Hrvatski
 日本語
Self-balancing robot
Two wheels and a gyro. A PID loop keeps it upright and you will finally understand what PID means.
5 parts$19.11
Things used in this project
Hardware components
-
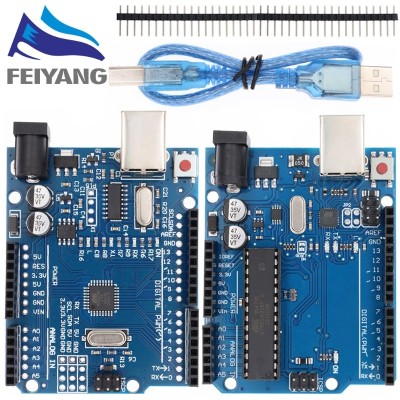
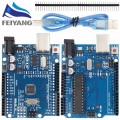 Uno R3 Compatible Board (ATmega328P, CH340, Pin Headers)
×1
$6.69
Where to buy
-
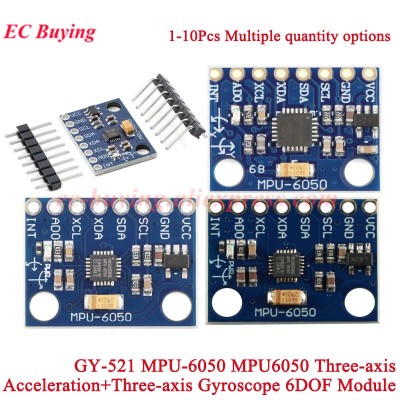
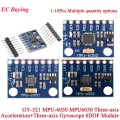 MPU-6050 Gyroscope and Accelerometer (GY-521)
×1
$1.29
Where to buy
-
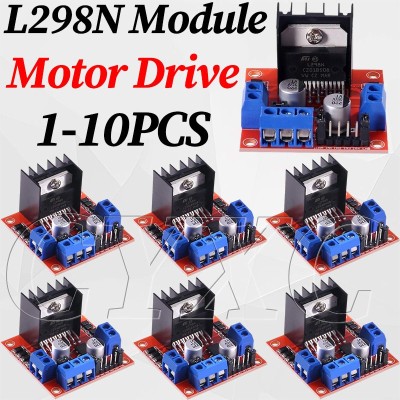
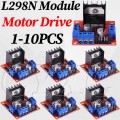 L298N Dual H-Bridge Motor Driver
×1
$2.85
Where to buy
-
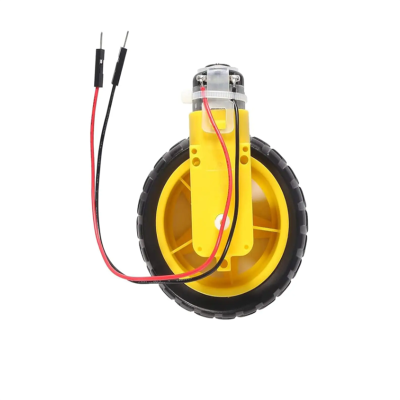
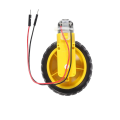 4x TT Gear Motor 1:48, Dual Shaft (3-6 V)
×1
$7.19
Where to buy
-
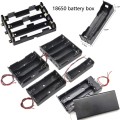 18650 Battery Holder Box (Weld-Free)
×1
$1.09
Where to buy
Software apps and online services
- Arduino IDE
Hand tools and fabrication machines
- Phillips screwdriver
- Multimeter
Story
- 01
Build a tall two-wheel frame from the chassis kit
- 02
Read angles from the MPU6050 over I²C
- 03
Tune the PID loop
- 04
Push it gently and watch it recover
More projects
Create a project
 Beginner
Obstacle-avoiding robot car
Four wheels, one ultrasonic eye. The car drives until it sees a wall, looks left and right, and picks the free way.
 Intermediate
Your first 5" FPV quad
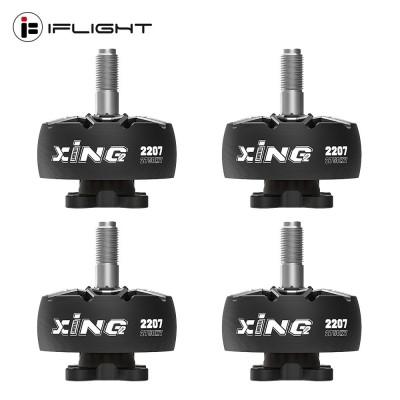
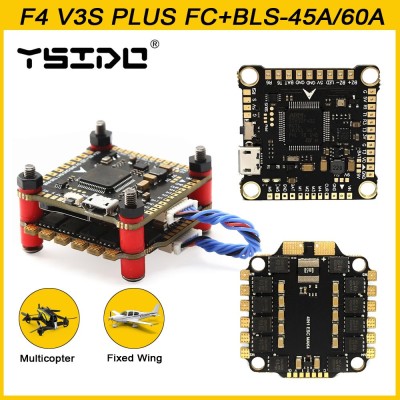
A freestyle quad you build yourself: carbon frame, four 2207 motors and a 3S pack for calm first flights.
 Beginner
Wi-Fi motion logger
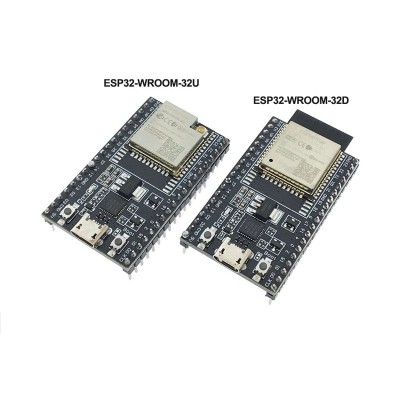
An ESP32 that records movement and shows it live on a page in your browser. No cloud needed.